Luyện nói tiếng Anh bằng Shadowing qua video: Turn a Time-of-Flight Sensor into a 3D Scanner

Chọn chế độ luyện tập

Mỗi chế độ mở một phòng luyện tập toàn màn hình.

139 câu
Nếu các câu quá ngắn hoặc quá dài, hãy bấm Edit để chỉnh sửa.
1
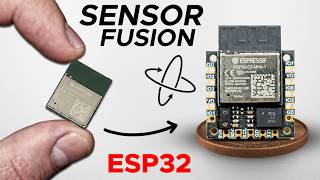
Today I want to show you a little setup that I've got here on the breadboard.
2
These are all parts from Aliexpress so it's a relatively cheap setup.
3
The ESP cost me about £4, the time of flight sensor cost me about £5 and this IMU was about £15.
4
So it's the most expensive part of the system and if we wanted we could replace it with a cheaper alternative.
5
So this whole setup cost about £24, that would be $30 or €28.
6
Eros.
7
So the reason why this tiny LiDAR is so special is that it is a multi -zone time -of -flight sensor.
8
So what that means is that instead of shooting out a single ray
9
and measuring the distance at which that ray bounces off an obstacle, it shoots out a 8x8 grid.
10
So those are 64 rays coming out of it that will bounce back once they hit an obstacle.
11
Now I've connected the breadboard to my computer via a USB cable and the LED is on so we know it's powered.
12
Here in the viewer now we can see that we've got roughly the same layout for the two breakout boards.
13
We have the IMU in purple and the time -of -flight sensor in green.
14
Here on the right we have the status panel showing the live data
15
and we can see that the IMU is connected
16
and we're getting measurement data from the time -of -flight at about 15 Hz.
17
Now you see these blue rays shooting out from the time -of -flight sensor.
18
There are 64 of them arranged in an 8x8 grid and each represents one zone that the sensor can measure.
19
Notice how they don't start right at the sensor, there's a small gap.
20
And they extend outward, but not infinitely.
21
If I zoom out, you can see that.
22
These line segments span the sensor's measurable range from 2 cm to 4 m.
23
Now, this is fundamentally different from how cameras work.
24
A camera captures light across a continuous image, but the sensor, it can only measure along these specific rays.
25
The points you see here, they're locked to these line segments.
26
They cannot appear anywhere else
27
and you can see as I slide my hand across the sensor you see the points going left
28
and right and also back and forth
29
and I can also hold my hand like this
30
and just slide my finger underneath it
31
and you can see there's a wave changing the points from the from the palm of my hand
32
now here's where it gets interesting let me zoom out
33
and we will see the points here that are projected onto the ceiling of the room where I'm at.
34
And you see in the settings panel this option here for clipping to measurement.
35
Let me enable it and let's see what happens.
36
Do you see how the rays now stop at the measure points instead of extending to the maximum range?
37
This is a much more accurate representation of what's actually physically happening.
38
The sensor shoots out infrared laser pulses.
39
They travel along these paths, bounce off of whatever obstacle they hit, and reflect back.
40
The sensor measures how long that took, that's the time of flight, and calculates the distance.
41
So when I hover my hand over the sensor, you can see some rays clip at my hand while others continue to the ceiling behind it.
42
And that's exactly what's happening in the real world.
43
Some laser pulses are hitting my hand, others are missing it and hitting the ceiling.
44
I think this visualization does a much better job of conveying what this sensor does compared to some 2D heatmaps
45
that you typically see online.
46
And it's a lot of fun to play with.
47
Alright, I've zoomed back in because I want to talk a bit about this purple breakout board here.
48
It's an IMU.
49
And watch what happens in a visualizer when I rotate the breadboard in the real world.
50
It also rotates.
51
The IMU on the breadboard is tracking the orientation in real time
52
and since both the IMU
53
and the time -of -flight sensor are stuck to the same breadboard we always know which direction the sensor is pointing.
54
Let me zoom back out and you can kind of see how if I point around I
55
can measure different points around my room.
56
Let's place the breadboard back on the table you may notice
57
that the points are a bit jittery
58
and that's just sensor noise from radiation coming from the window or noise from the actual sensor measurement.
59
Now if I come over here to the side panel
60
and enable that filter you can see how the noise kind of smooths out
61
and I can control the strength of the filter with this slider.
62
What's happening under the hood is an exponential moving average.
63
At 0 .5 strength, each new position is calculated as 50 % of the new measurement plus 50 % of the previous position.
64
So it's essentially averaging the current and previous readings.
65
If I crank up the strength to 0 .9, it gets even smoother.
66
But now there's a noticeable lag.
67
So when I move this two -point from the ceiling to the wall, you can see that the points are really smooth,
68
but there's a noticeable delay.
69
At 90 % previous and only 10 % new measurement, the visualization can't keep up with the fast movements.
70
So it's a trade -off between smoothness and responsiveness.
71
If I move the strength all the way down to 0, that essentially means there is no filter.
72
It's the same as if this checkbox was left unchecked.
73
And watch what happens if I move all the way to 1.
74
That means that the previous measurement gets all the weight and 0 % is assigned to the new measurement.
75
So even though I'm rotating the breadboard around the room, you see that no new measurements are coming in.
76
Let me move the slider back to 0 .5, which I found to be a good strength for the filter.
77
Alright, let's move on to the next section.
78
The viewer can also fit the plane to the measured points.
79
When I enable plane fitting with the least squares method and point the sensor at a flat surface like the ceiling,
80
you can see if it's a nice plane.
81
But watch what happens when I point the sensor at both the wall and the ceiling at the same time.
82
The fitted plane ends up diagonally, trying to minimize the error across all points, and this is not very useful.
83
This is where RANSAC comes in.
84
RANSAC stands for Random Sample Consensus.
85
When I switch to this method, watch how it behaves differently.
86
RANSAC works by randomly picking three of these sampled points, the minimum to define a plane.
87
Fitting a plane to those three, then checking how many other points lie close to that plane,
88
and it repeats this about a hundred times and keeps the best fit.
89
The key difference is, instead of trying to please all the points equally,
90
Ransack finds the plane that the majority of points agree on and ignores the outliers.
91
So now when I point again at both the ceiling and the wall, it snaps to whichever surface has more points.
92
Rather than compromising with a meaningless diagonal.
93
And so even if I come in with a pen to disturb the sensor measurements,
94
you can see how it still is able to be robust to that and fit the ceiling nicely.
95
And if I change to least squares,
96
you see how much the disturbance from waving this pen on top of the sensor affects the fitted plane.
97
I'm going to change again to RANSACK now.
98
If you cover enough points you can see that it still affects the plane fitting algorithm,
99
but most of the time it behaves much better than least squares.
100
I've changed to least squares again.
101
I'm just hovering the pen back and forth and I'm gonna change to RANSACK again.
102
It's a really big difference.
103
Up until now we've been showing the current snapshot seen by the sensor.
104
In other words, the viewer is only showing the points that the sensor sees right now at any given point in time.
105
When new measurements come in, the old points disappear and that's why it is so interactive.
106
Mapping mode changes that.
107
Instead of replacing points, it accumulates them.
108
So watch what happens when I hover my hand over the sensor with mapping mode enabled.
109
You can see points starting to build up in the shape of my hand's movement,
110
and covering most of the sensors point field of view up close almost like a truncated pyramid.
111
Okay I've zoomed back out and cleared them up.
112
Here's where the magic really happens.
113
You remember we have the IMU tracking orientation right?
114
So watch what happens when I rotate the breadboard.
115
Look at that!
116
The accumulated points are building up a map of the room so I can see the walls, the ceiling, my monitor, my desk,
117
if I go under the desk I can see the floor
118
and if I point at myself you'll even be able to see me
119
and I can even put my left arm up
120
and then my right arm up and
121
because we're no longer just showing the instantaneous points
122
that the sensor is measuring we've just accumulated them we essentially have a map of the room we have a mapping device
123
Now, the reason why this works is because the IMU knows exactly
124
which direction the sensor is pointing at as I rotate it, and each measurement gets placed in the correct position in 3D space,
125
and they all accumulate into a coherent point cloud.
126
This is really cool!
127
With just an ESP32, a time -of -flight sensor, and an IMU, we've essentially built a simple 3D mapping device.
128
Now there's one limitation worth mentioning.
129
The IMU is excellent at measuring rotation, but it cannot accurately track translations, moving the sensors side to side or forward and back.
130
So if I walk around with a breadboard, the map will drift and become inaccurate.
131
For best results, I always try to rotate the sensor in place without translating too much, just like this.
132
Within that constraint, you get surprisingly good results from such a simple and cheap setup.
133
And that's it!
134
This concludes the video.
135
I think this demo really shows how powerful the combination of a multi -zone time -of -flight sensor
136
and an IMU can be.
137
And for around $30 in parts, you can build something that gives you a real intuition for what the sensors are actually measuring
138
and could be useful for a robotics project.
139
Thanks for watching and I'll see you in the next one!

Tải Ứng Dụng

Mọi thứ bạn cần để nói trôi chảy

Chấm điểm AIChấm từng câu nói
Luyện IPAThành thạo mọi âm
Từ vựngMở rộng vốn từ
Game Từ vựngHọc qua chơi
FOR YOU

Video gợi ý

Từ vựng và ghi chú luyện nói cho bài học này

Bài luyện nói này dựa trên video “Turn a Time-of-Flight Sensor into a 3D Scanner”. Những từ được nhắc lại nhiều nhất trong bài: sensor, Imu, measurement, plane, breadboard. Video này có 42 câu và 1785 từ để luyện shadowing. Phần lời nói dài 11:19. Người nói nói với tốc độ tự nhiên, khoảng 158 từ mỗi phút, gần với hội thoại hằng ngày. Chỉ 78% số từ nằm trong 3.000 từ tiếng Anh thông dụng nhất, nên từ vựng khá khó.

Từ vựng quan trọng trong video

15 từ đáng học trong video, kèm phiên âm và nghĩa:

TừPhiên âmNghĩa
sensor danh từ/ˈsɛn.sɚ/cảm biến
ceiling danh từ/ˈsilɪŋ/trần, trần nhà
filter danh từ/ˈfɪltɚ/máy lọc
bounce động từ/baʊns/nảy
viewer danh từ/ˈvju.ɚ/khán giả, người xem
obstacle danh từ/ˈɑbstəkəl/bước cản, chướng ngại
desk danh từ/dɛsk/bàn
connect động từ/kəˈnɛkt/nối
extend động từ/ɛkˈstɛnd/kéo dài
purple danh từ/ˈpɝ.pl̩/tía
slide danh từ/ˈslaɪ̯d/cầu trượt, cầu tuột
laser danh từ/ˈleɪzɚ/la-de, kích quang
grid danh từ/ɡɹɪd/lưới, mạng
pulse danh từ/pʌls/mạch
behave động từ/bɪˈheɪv/cư xử

Cụm động từ bạn sẽ nghe

TừPhiên âmNghĩa
zoom out động từ/ˌzuːm ˈaʊt/thu nho

Những câu đáng luyện lại

Các câu ngắn, trọn ý trong video mà bạn có thể dùng lại khi giao tiếp hằng ngày:

  • Let me enable it and let's see what happens.
  • Let's place the breadboard back on the table.
  • All right, let's move on to the next section.
  • I've changed to least squares again.

Ngữ pháp trong video

Những cấu trúc người nói dùng nhiều nhất, kèm đúng cụm từ trong video:

Cấu trúcTrong video
Câu điều kiện if + mệnh đề, will/would + động từ — điều kiện và kết quảif I point at myself you'll even
Thì hiện tại hoàn thành have/has + quá khứ phân từ — việc đã xảy ra nhưng còn liên quan đến hiện tạiI've connected · I've zoomed · I've changed
Câu bị động be + quá khứ phân từ — nhấn vào việc xảy ra, không phải người làmis connected · are projected · is calculated

Phát âm cần chú ý

Người nói dùng 21 dạng rút gọn, ví dụ I'm, I've, we've. Hãy nói theo dạng ngắn đúng như bạn nghe.

  • Âm “th”: smooth /smuːð/, underneath /ˌʌndɚˈniθ/, algorithm /ˈælɡəɹɪðm̩/
  • Âm “sh” và “zh”: measurement /ˈmɛʒ.ə.mənt/, essentially /ɪˈsɛnʃəli/, orientation /ˌɔː.ɹi.ənˈteɪ.ʃən/, capture /ˈkæp.(t)ʃɚ/, translation /tɹænzˈleɪʃən/
  • Từ dài — đặt trọng âm cho đúng: essentially /ɪˈsɛnʃəli/, orientation /ˌɔː.ɹi.ənˈteɪ.ʃən/, representation /ˌɹɛp.ɹə.zɛnˈteɪ.ʃən/, radiation /ˌɹeɪ.diˈeɪ.ʃən/, differently /ˈdɪf.ə.ɹənt.li/

Những âm người Việt thường gặp khó:

  • Cụm phụ âm cuối — đọc đủ từng âm, đừng nuốt âm cuối: measurement /ˈmɛʒ.ə.mənt/, bounce /baʊns/, desk /dɛsk/, connect /kəˈnɛkt/, extend /ɛkˈstɛnd/
  • Âm /tʃ/, /dʒ/ và /ʒ/ — tiếng Việt không có, đừng đọc thành “ch” hay “gi”: measurement /ˈmɛʒ.ə.mənt/, arrange /əˈɹeɪnd͡ʒ/, whichever /wɪt͡ʃˈɛvɚ/, visualization /ˌvɪʒ.ʊ.ə.laɪˈzeɪ.ʃən/, checkbox /ˈt͡ʃɛkbɑks/
  • Âm /æ/ — mở miệng rộng hơn âm “e”: calculate /ˈkælkjʊleɪt/, capture /ˈkæp.(t)ʃɚ/, translation /tɹænzˈleɪʃən/, snap /snæp/, interactive /ˌɪn.tɚˈæk.tɪv/

Cách luyện với video này

  1. Nghe hết video một lần, chưa cần nói, và ghi lại những từ bạn chưa biết.
  2. Bắt đầu ở tốc độ 0,75×, nói đuổi từng câu, rồi quay lại tốc độ bình thường khi đã quen.
  3. Ghi âm giọng mình rồi so với bản gốc, chú ý các từ như sensor, ceiling, filter.

Phương Pháp Shadowing Là Gì?

Shadowing là kỹ thuật học ngôn ngữ có cơ sở khoa học, ban đầu được phát triển cho chương trình đào tạo phiên dịch viên chuyên nghiệp và được phổ biến rộng rãi bởi nhà đa ngôn ngữ học Dr. Alexander Arguelles. Nguyên lý cốt lõi đơn giản nhưng cực kỳ hiệu quả: bạn nghe tiếng Anh của người bản xứ và lặp lại to ngay lập tức — như một "cái bóng" (shadow) đuổi theo người nói với độ trễ chỉ 1–2 giây. Khác với luyện ngữ pháp hay học từ vựng bị động, Shadowing buộc não bộ và cơ miệng phải đồng thời xử lý và tái tạo ngôn ngữ thực tế. Các nghiên cứu khoa học xác nhận phương pháp này cải thiện đáng kể phát âm, ngữ điệu, nhịp điệu, nối âm, kỹ năng nghe và độ lưu loát khi nói — đặc biệt hiệu quả cho người luyện IELTS Speaking và muốn giao tiếp tiếng Anh tự nhiên như người bản ngữ.

Phương pháp shadowing: đọc hướng dẫn từng bước đầy đủ →